Ask two engineers how a waste gasifier should be run and you can get answers a decade apart. One describes a trained operator at a panel, setting the air by judgement. The other describes a learned model writing setpoints inside the control cabinet. Both are describing plants that exist. The disagreement is not about which technology works, but about which rung of an escalation a given plant has earned.
A waste gasification control strategy is the arrangement of measurement, model and actuation that holds a gasifier inside its operating window: hot enough in the oxidation zone to crack tar, cool enough at the grate to avoid slagging, and steady enough in gas quality that the engine or synthesis step downstream keeps running. There are four rungs in practice, and each exists because the one below it has a documented failure mode. On waste those failure modes share a root: the feedstock changed and the controller did not know.
Why most waste gasifiers still run on judgement
The state of the art is less advanced than the literature on gasification chemistry suggests. A 2024 control study from TU Wien opens by noting that dual fluidized bed gasification plants mainly rely on manual operation or single-input single-output control loops, and that scientific contributions exist only for controlling individual process variables. A study on a commercial downdraft gasifier makes the same point from the bottom of the market: the gasifiers sold so far do not control the air flowing into the reactor at all. When the pressure inside the reactor rises, less air is drawn in, the syngas composition shifts, the engine misfires and the power output drops.
Manual operation persists because a trained operator is a working soft sensor. They combine the readings, the feed and the behaviour of the plant into an estimate no single instrument produces, and act on it before an analyser could confirm it. The limitation is not that the estimate is poor. It is that it exists in one person, cannot be audited, and does not transfer to the next shift or the next plant. On waste that baseline is harder to hold than on wood pellets, because the composition and moisture of the feed move within a single load.
Closing one loop: what a single measurement buys
On a downdraft fixed bed gasifier running wood pellets, a Korean study added a single PID controller holding the air flow into the reactor constant, and compared two days of operation. Without control, the heating value of the syngas averaged 1,559 kcal per cubic metre with a standard deviation of 110, a fluctuation of about 7 percent. With the loop active, the average rose slightly to 1,590 and the standard deviation fell to 36, a fluctuation of 2.3 percent. One loop, on one variable, cut the gas quality variation by roughly a factor of three.
The second escalation is to infer what you cannot measure from things you can. Work on a downdraft gasifier fed with refuse derived fuel from municipal solid waste built a feedback controller around the temperature difference between the oxidation and reduction zones. That difference indicates whether the char bed is running endothermic or exothermic, a proxy for the oxidising agent being in surplus or deficit, and the controller adjusts the fuel feed rate to hold it at target. Over more than 70 hours of continuous operation the zone temperature fluctuation fell from above 100 degrees Celsius to below 50, the differential band narrowed from plus or minus 200 degrees to plus or minus 50, and the lower heating value went from 6.2 plus or minus 3.1 megajoules per normal cubic metre to 5.7 plus or minus 1.6. The mean dropped a little. The scatter halved. On a waste stream the scatter is what fouls the cleaning train and stops the engine, so that is the trade you want.
Tar: what actually predicts it, and what the loop still does not know
Tar decides whether a waste gasifier is commercially viable. The TU Wien study on the pilot plant and the industrial plant at Senden states the consequence plainly: high tar content makes operation uneconomic through sharply diminished gas quality, and causes unexpected shutdowns when the product gas coolers foul. The standard measurement is the tar protocol, whose sampling and laboratory analysis take at minimum an hour and up to a day. That delay, rather than any difficulty in the chemistry, is why tar is not controlled on a routine basis.
The reflex is to conclude that tar is therefore invisible to a controller. It is not. A lab-scale study at Graz, built on more than 80 experimental points spanning 700 to 800 degrees Celsius, two feedstocks, varying steam and added oxygen, ranked the predictors against gravimetric tar. Freeboard temperature came first, with a coefficient of determination of 0.83, ahead of hydrogen at 0.82 and methane at 0.70, and it was the only correlation that survived the addition of oxygen to the fluidising steam. Carbon monoxide and carbon dioxide showed no relationship at all, the same null result the TU Wien work found independently at pilot and industrial scale.
So the best single online predictor of tar is a thermocouple, on a plant that already has one. The catch is that the correlation is a fit rather than a law. It has to be calibrated on the specific gasifier, the probe position must be found individually for each reactor, and the Graz authors are explicit that a correlation working in one case can fail in another. Dedicated online tar analysers do exist, flame ionisation instruments validated against the tar protocol to within about 20 percent, but they are laboratory-grade equipment rather than standard plant instrumentation.
The distinction that matters, then, is not visible against invisible. A loop holding reactor temperature is already, silently, holding tar inside a band. What it is not doing is reporting the number, noticing when the correlation stops holding after a feedstock change, or trading tar against the yield that suppressing it costs. Those need a model rather than a loop.
Model-based control: closing the loop on a model instead of a measurement
Instead of reacting to what a sensor reports, a model-based controller simulates the process forward and acts on the predicted trajectory, subject to the constraints of the plant. The clearest demonstration on a gasifier is the TU Wien study cited above. Before the work, the 100 kilowatt pilot plant was operated manually. The authors replaced that with two model predictive controllers: a high-level one tracking product gas quantity and gasification temperature while holding a minimum oxygen content in the flue gas, and a lower-level one distributing air across three stages to hold the bed material circulation. The model inside is neither a neural network nor a fluid dynamics simulation. It is a set of mass and energy balances with plant-specific coefficients estimated from measurement data, running every 5 seconds, predicting on two time scales because gas flows change in seconds and reactor temperatures in tens of minutes, and carrying five disturbance states so that a mismatch between model and plant is estimated rather than ignored.
That last choice earned its place during the test. The dosing screws feeding biomass were miscalibrated, so the actual feed was 20 percent lower than the controller believed. The disturbance estimator absorbed it and the plant tracked its setpoints anyway, for more than eight hours, through step changes in both controlled variables. The paper is equally direct about the price: the model is linearised around an operating point, and moving the controller to a different plant means re-estimating heat capacities and heat transfer parameters from scratch. Model-based control shifts the risk from the plant to the model, and a plant that drifts away from its linearisation point hands that risk straight back. We set out the trade-off in more detail in our comparison of reinforcement learning and MPC for process control.
When the model is learned rather than derived
Every result above depends on a model written down by hand for one plant and one feedstock. On wood pellets that is a reasonable contract. On waste it is the weak point, because the composition, moisture and ash of the feed change between loads and within them, and each change moves the plant away from the point the model was fitted at. Fitting the dynamics from data instead of deriving them answers that, and the gasification literature now has two worked examples.
The first replaces the model inside the predictive controller. A 2024 study in Chemical Engineering Science puts a long short-term memory network at the centre of an MPC for fluidized bed gasification, regulating temperature in the bed, the freeboard and the outlet through primary air, secondary air and biomass feed, holding setpoints between 800 and 900 degrees Celsius to a steady-state error below 1.5 percent with a response under 5 seconds.
The second lets the model keep learning. A model-based deep reinforcement learning controller, trained on operational data from a pilot-scale gasification plant and updated periodically while running, beat a conventional predictive controller by more than 15 percent on syngas composition and flow rate, and matched it on temperature. Its own comparison is the more useful result: the predictive controller was better at temperature, the learning controller better at composition and at absorbing abrupt change.
The same caveat applies to both. The closed loop in the first was a computational fluid dynamics model of the gasifier, not the gasifier; the second was evaluated over 3,000 seconds of simulated operation. A learned controller for gasification has been demonstrated against a simulator, not shown holding a live waste-fed plant through a season of feedstock. That gap is the argument for treating sim-to-real transfer and a hard safety layer as part of the deliverable rather than a later step. A fitted model justifies trust with a validation record rather than a derivation, and needs a layer that can veto its output before an unsafe action reaches an actuator. It still sits inside the same loops underneath, and does not replace the fast air-flow loop.
The escalation on one page
| Rung | What it fixes | What it still cannot do | The measured evidence |
|---|---|---|---|
| Manual operation | Nothing. It is the baseline | Be audited, or survive a shift change | The default on most plants |
| One closed loop | Scatter in gas quality | See anything the loop does not measure | Heating value fluctuation from 7 to 2.3 percent |
| An inferred variable | The quantity no instrument reports | Trade one objective against another | Zone temperature swing from above 100 to below 50 degrees, over 70 hours |
| Model-based control | Several variables at once, under constraints | Hold once the plant leaves its linearisation point | Setpoints tracked eight hours through a 20 percent feed error |
| A learned model | Feedstock variability the fitted model covers | Claim anything without a validation record | Steady-state error below 1.5 percent, against a simulator rather than a plant |
What this is worth in Spain
Spain is a useful test of the argument, because the technology is barely deployed there and the reason is not technical. AVEBIOM counted seven industrial gasification plants and two pilot or demonstration plants in operation in 2023, and noted that gasification has no national roadmap, unlike biogas or hydrogen. The IEA's record of the 2012 royal decree explains the gap: after the decree removed the support scheme, most existing plants stopped and new biomass electricity projects were abandoned. The plants that survived did so on economics, not on proof of concept.
That makes availability the decisive variable, and availability is what a control strategy buys: an unplanned shutdown to clean a fouled cooling train is lost production on a plant whose margin was already the reason it nearly did not get built. Regulation points the same way. European rules tighten the landfill share of municipal waste to 10 percent by 2035, against roughly 30 to 35 percent in Spain today, which turns the residual fractions with no viable recycling route into a feedstock somebody has to process. Those are the fractions that vary most, and so the ones that punish a controller with no way of knowing the feed has changed.
Where our own plant sits on this ladder
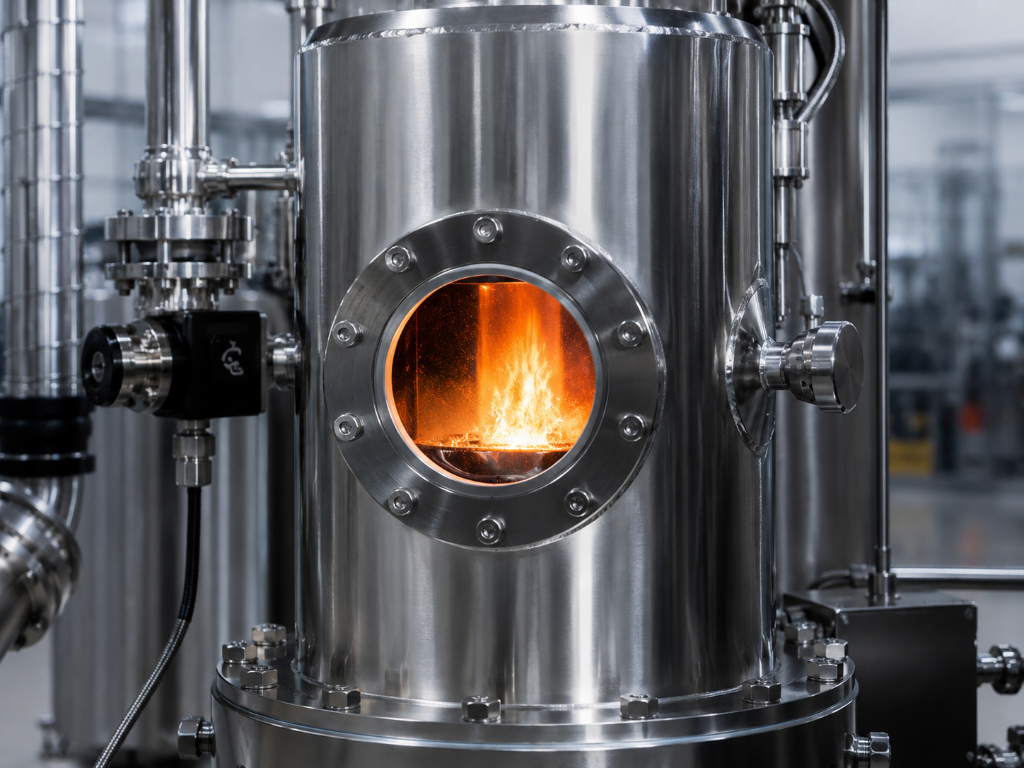
Equation Labs builds the X-150 Walzenrost platform, a containerised, modular downdraft fixed bed gasifier with a roller grate, switchable air and oxy-steam operation, and a catalytic tar reformer downstream of the reactor, that turns challenging waste streams into clean, carbon-negative syngas. It also develops the modelling and control systems that let industrial processes run themselves. The grate speed, the air-to-oxy-steam split and the feed rate are the variables the escalation above is arguing about, and the tar reformer is why tar has to be estimated online rather than discovered in the cleaning train.
The figures we quote for the control stack come from its validation on a 500 litre pilot cultivation basin. A basin is not a gasifier and the timescales are not comparable, but it shares the one property that decides how a learned controller has to be built: it cannot be crashed to generate a training episode. On that process the learned model reaches an R-squared above 0.95, the safety layer answers in under 2 milliseconds, end-to-end edge latency is 285 milliseconds reduced from 1.2 seconds, and sim-to-real validation ran across 400 simulated years with zero recorded safety violations. Read the simulated years as coverage of the state space, not elapsed operating time. The method is the one running through every result above: derive the equations first, fit what they cannot give you, put a hard safety layer in front of it, and hand over the record that lets someone else re-run it.
FAQ
What is a waste gasification control strategy?
It is the arrangement of measurement, model and actuation that keeps a gasifier inside its operating window — hot enough to crack tar, cool enough to avoid slagging, steady enough in gas quality for the downstream engine or synthesis step. On waste it has to cope with feedstock that changes between loads and within them.
Which control rung should a waste gasifier start at?
At the one below the failure you are seeing. Gas-quality scatter stopping downstream equipment is the case for a loop on air. A quantity no instrument reports is the case for an inferred variable. Several objectives that have to be traded is the case for a model. Feedstock variability that a hand-derived model can no longer cover is the case for a learned model, with the validation record and safety layer built before the first live run.
Why is tar not controlled directly?
Because the reference measurement, the tar protocol, needs an hour to a day of sampling and laboratory analysis. That delay makes closed-loop control on measured tar impractical. Freeboard temperature correlates with tar closely enough (an R-squared around 0.83 in published work) to act as an online proxy, but only after it is calibrated on the specific reactor.
Does a learned controller replace the basic loops?
No. A learned model sits on top of the same fast air-flow and regulatory loops underneath it. What it adds is adaptation to feedstock the hand-derived model was not fitted for, plus a safety layer that can veto its output before an unsafe action reaches an actuator.
Choosing a waste gasification control strategy for your own plant
The literature does not converge on one best strategy, because there is not one. It converges on an order, each rung justified by a specific failure of the one before it.
Climb when the rung you are on stops seeing the thing that is hurting you, and not before. Gas quality scatter stopping the equipment downstream is the case for a loop on air. A quantity no instrument reports is the case for an inferred variable. Several objectives that have to be traded against each other is the case for a model. And feedstock variability that has outrun what a hand-derived model covers is the case for a learned one, with the validation record and the safety layer built before the first live run rather than after, because a gasifier, unlike a robot, does not give you a second attempt on the same afternoon.
That order, and the evidence each rung has to carry, is the method we bring to contract research and development for industrial control. If choosing a waste gasification control strategy is the conversation you are in, talk to the team.